Nav2 Configuration for Autonomous Mobile Robots
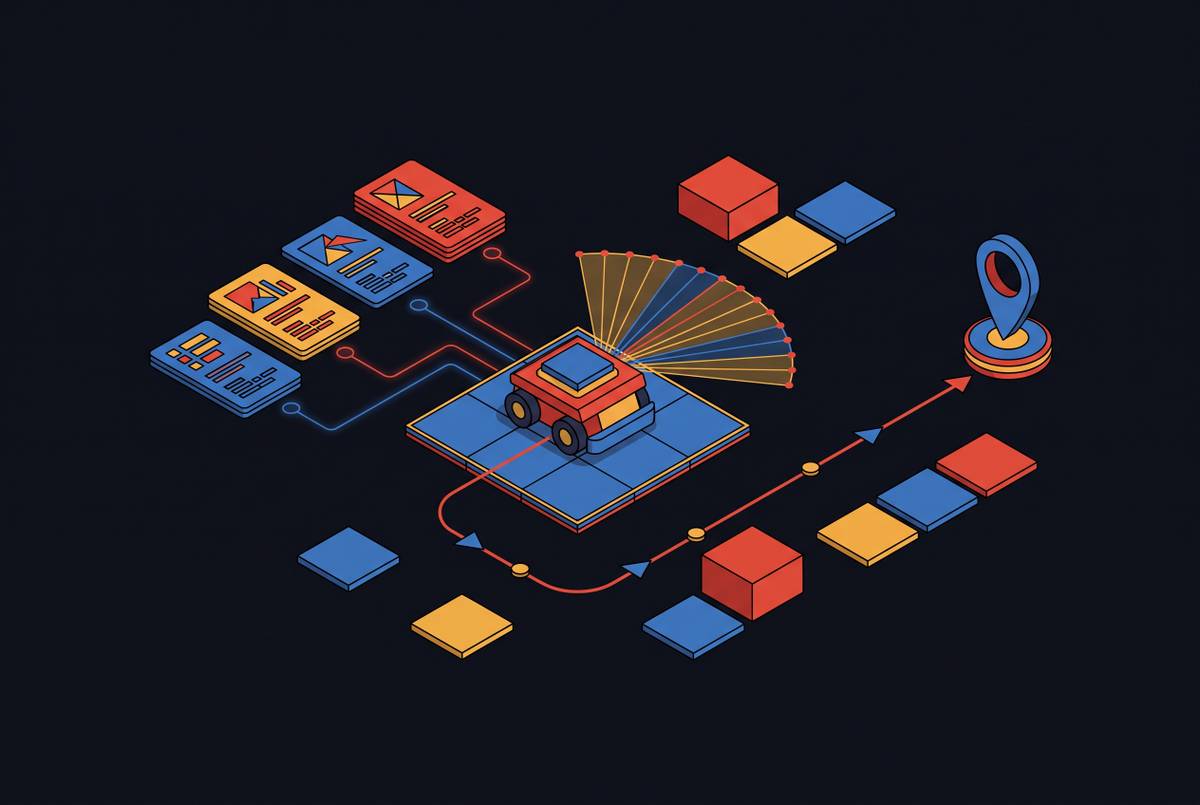
Understanding dependency chains and behavior trees prevents silent configuration failures.
Marcus Yuen
4 stories
Understanding dependency chains and behavior trees prevents silent configuration failures.
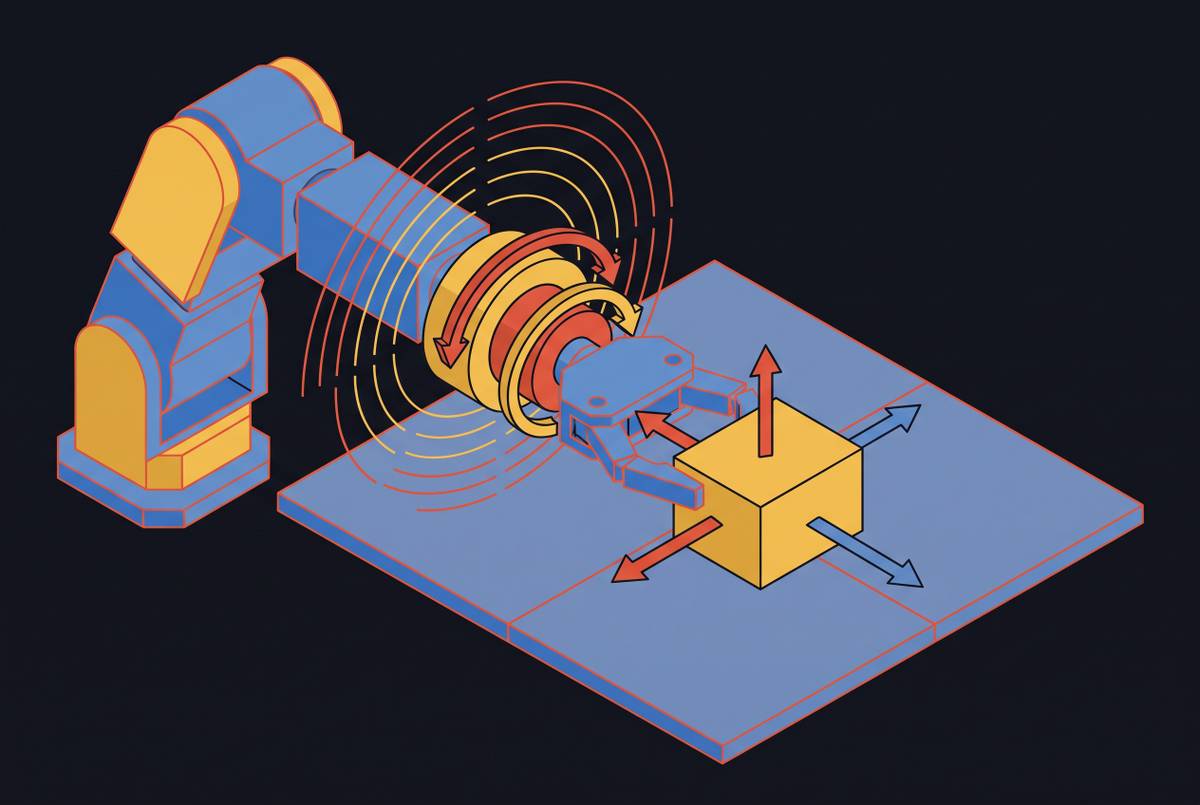
Force sensing enables robots to recover from contact failures that vision alone cannot fix.
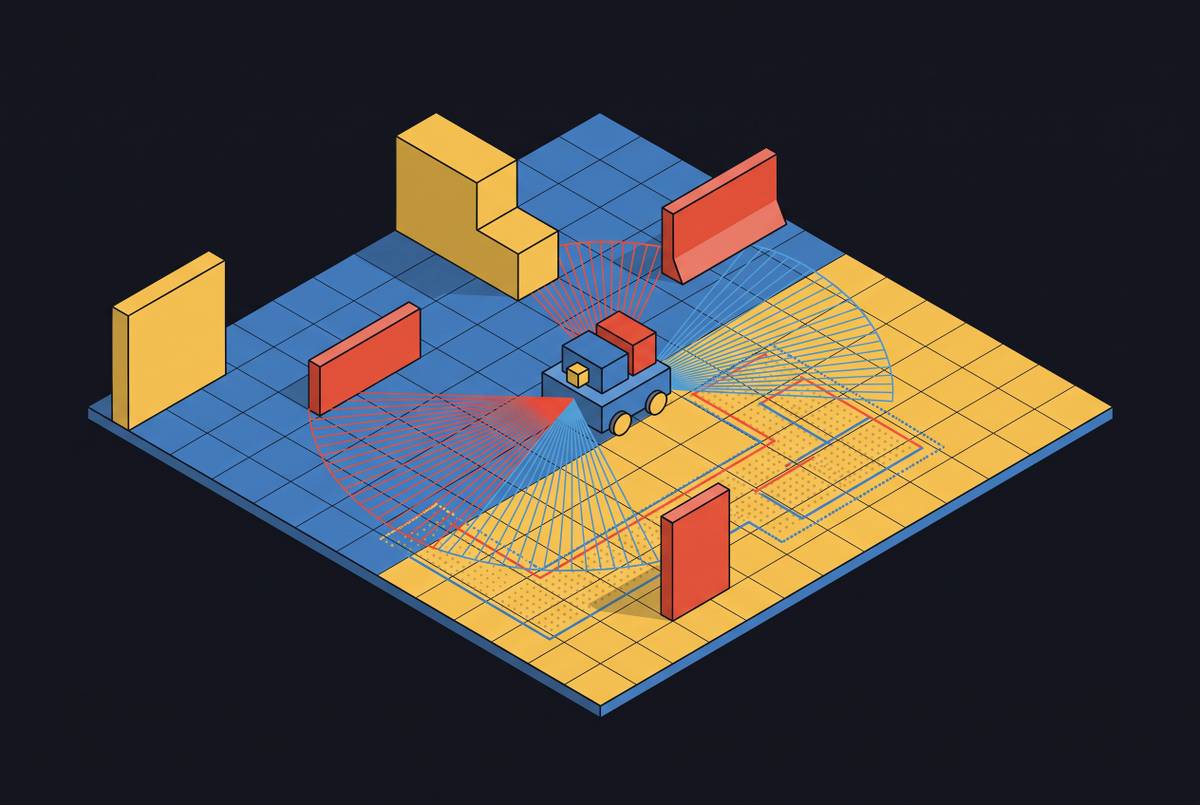
Filter-based, matching-based.
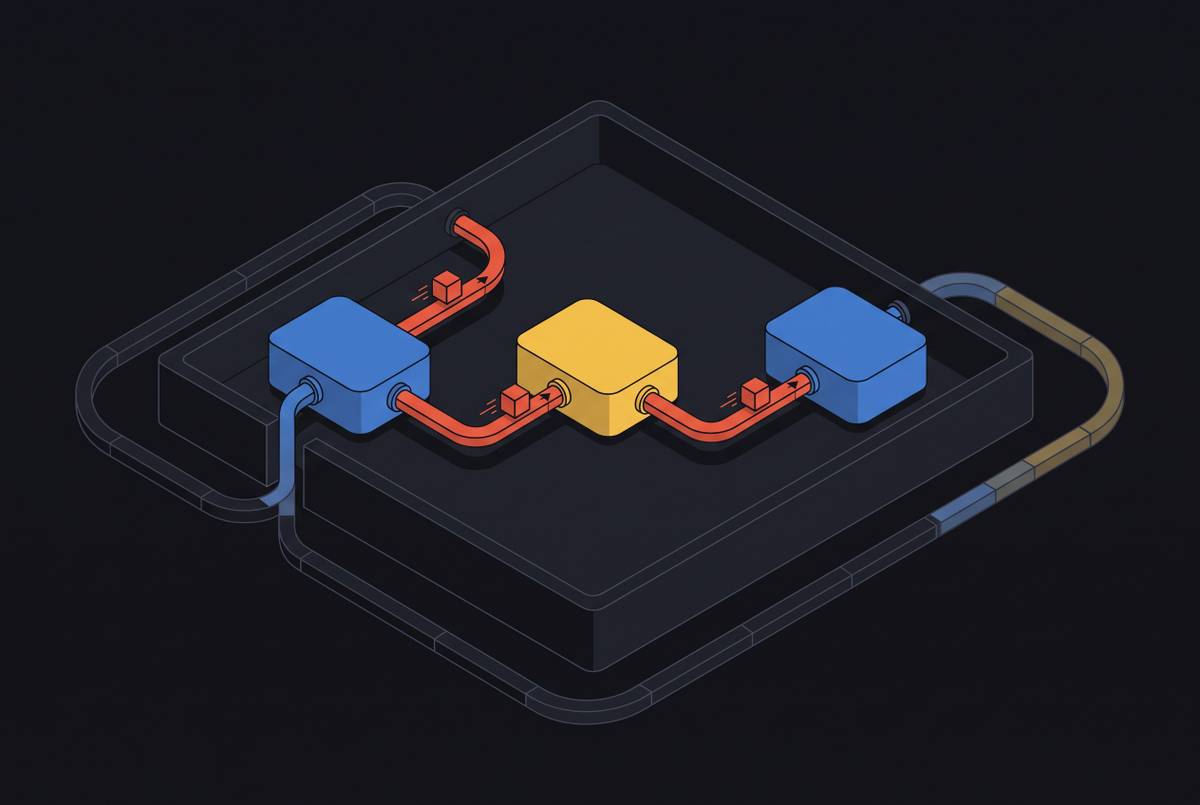
Shared-process communication trades fault isolation for zero-copy speed.